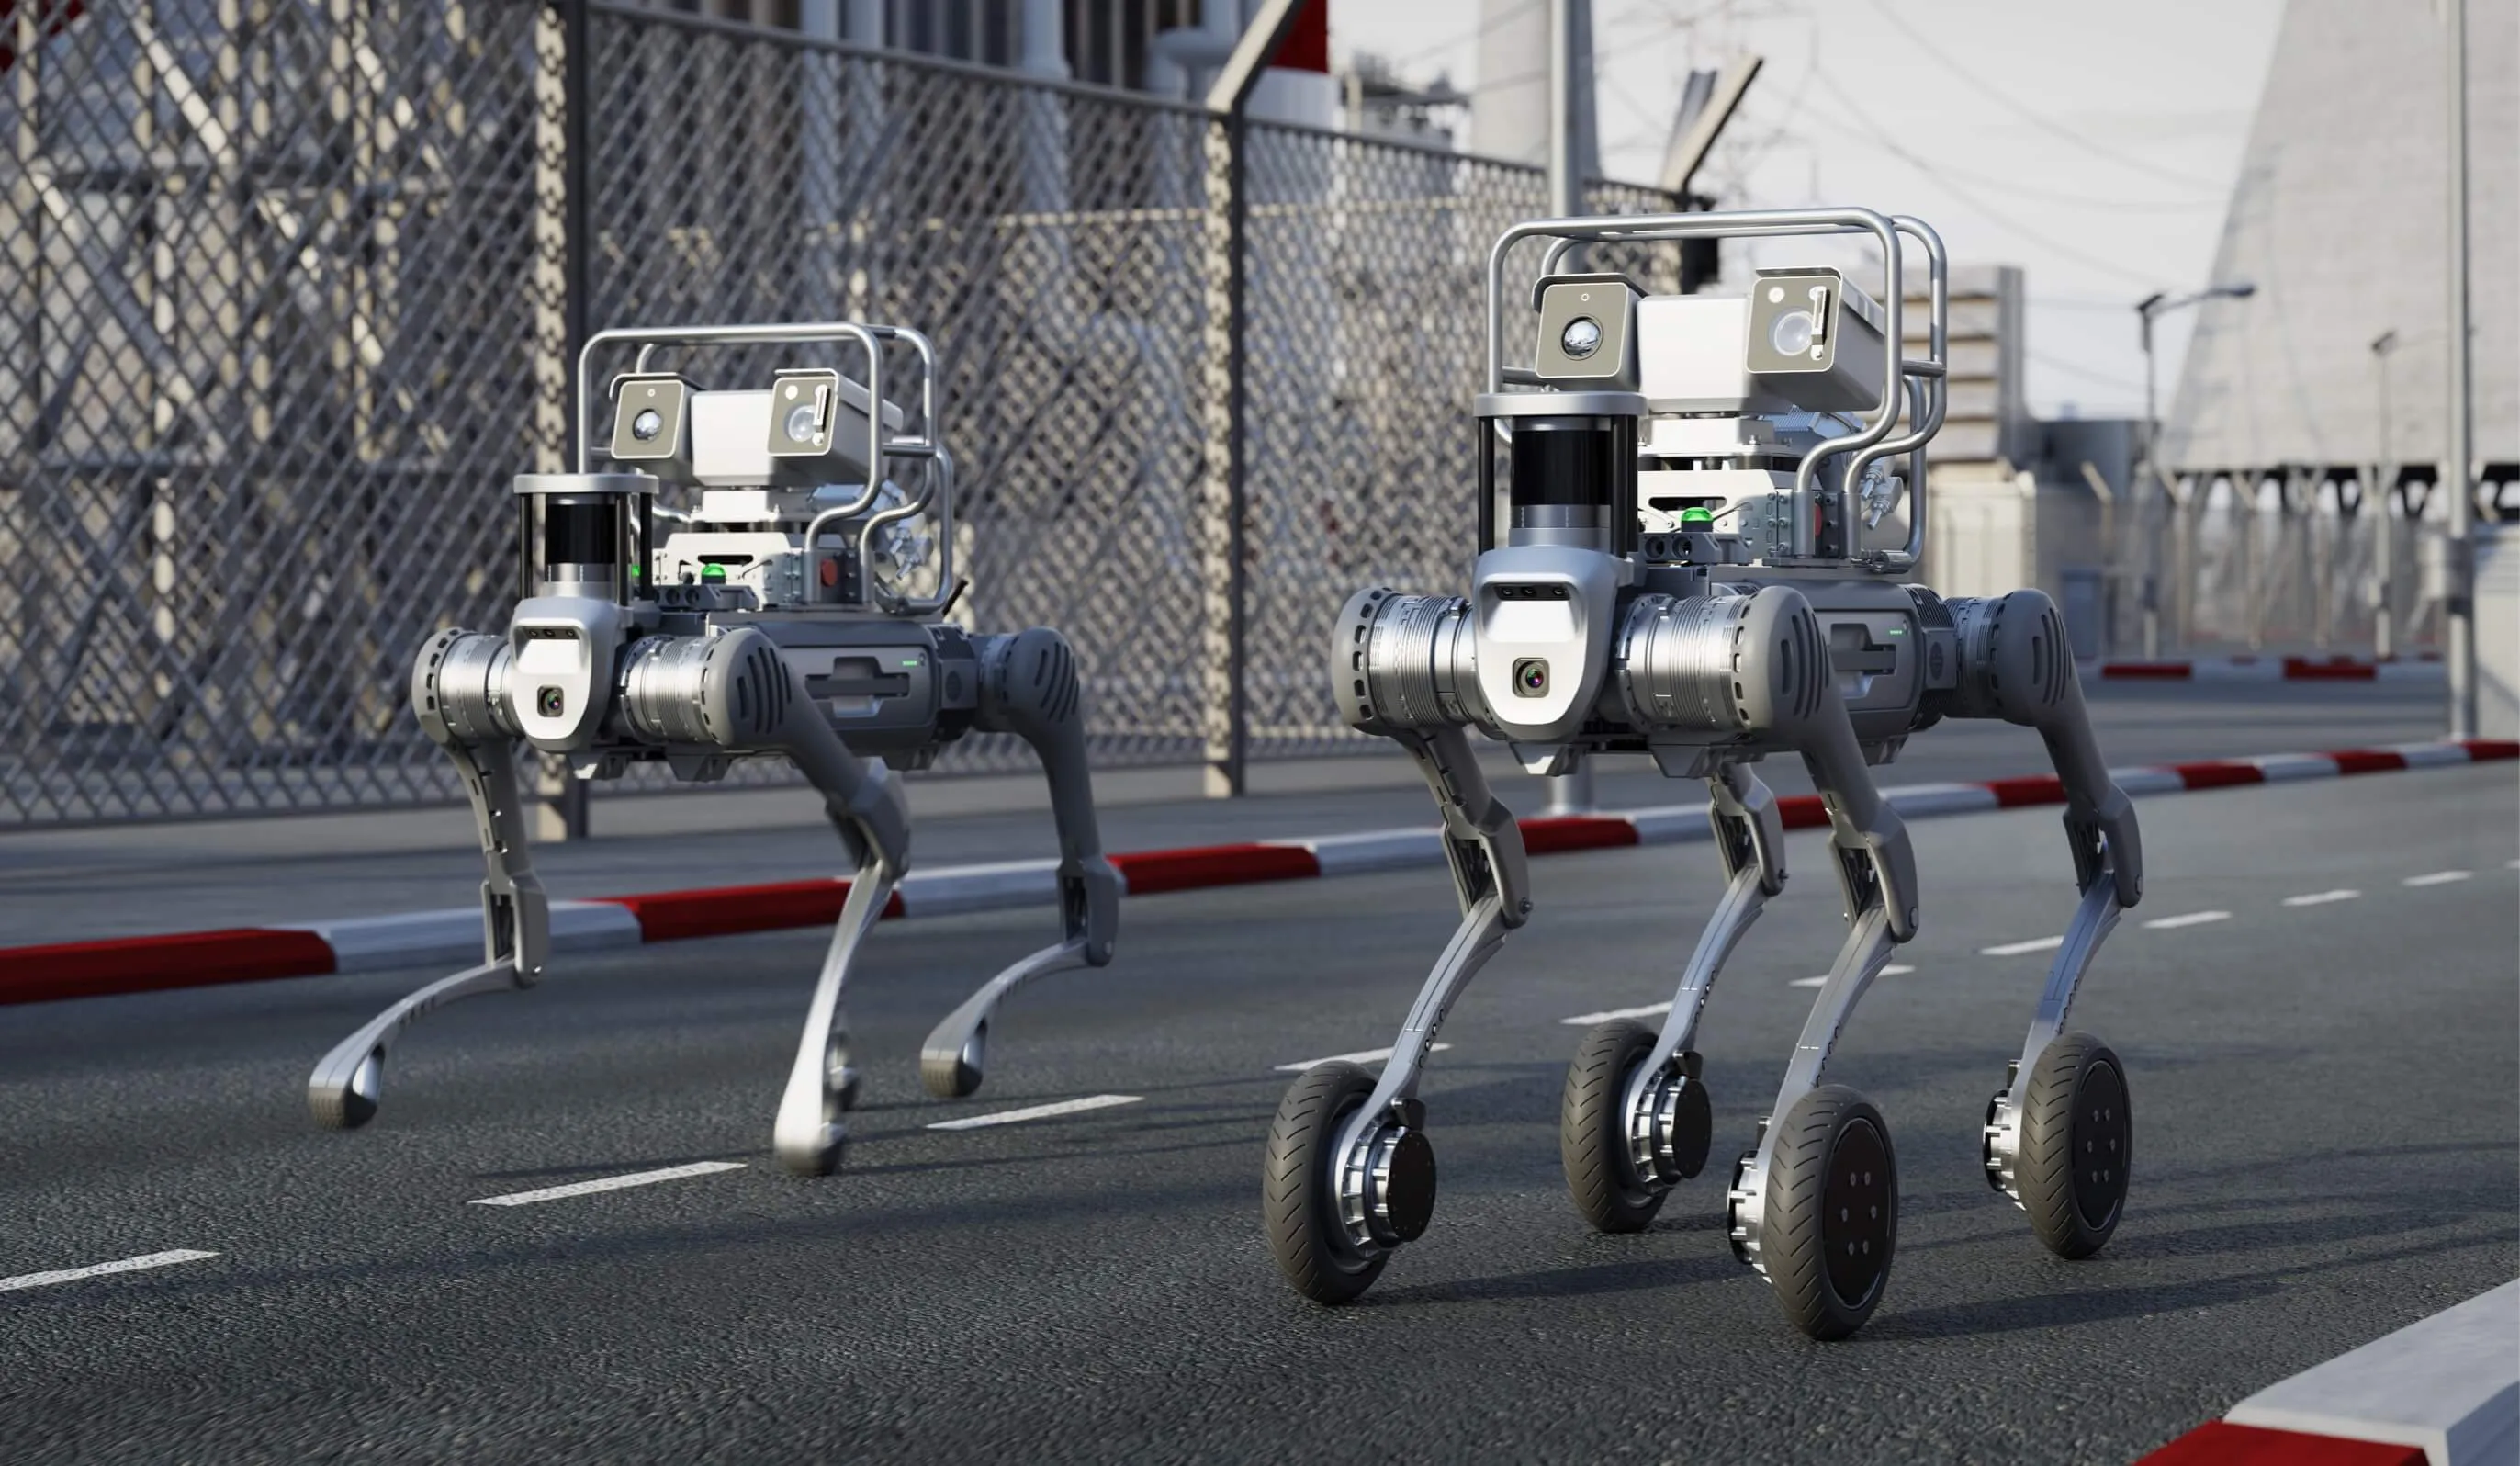
The team reports the manufacturer's stock controller caused a thermal shutdown after 1.4 km when the rear-left hip motor hit 85°C, because "wheel-based locomotion caused load concentration at the hip joints"; their own load-distributing policy let the robot complete the full ~2.8 km route across six runs without overheating, and its rough-terrain policy handled stairs up to 24 cm and an 18-step staircase.
- Completed a 2.8 km real-world route including sidewalks, a park, and stairs without stopping for overheating once a custom control policy was used
- Rough-terrain policy climbed stairs up to 24 cm plus an 18-step staircase and unpaved terrain
- Sustained 51 minutes of continuous operation at 1.0 m/s with temperature plateauing around 60°C
- Stock manufacturer controller overheated the hip motor to 85°C and triggered thermal shutdown after only 1.4 km
- Wheeled locomotion inherently concentrates load/heat at the hip joints without a custom policy
- Two of six runs needed human intervention, and the robot could not reliably detect/avoid fast-moving objects like cars
Leggi la recensione completa su arXiv (Chiba Institute of Technology, fuRo) →