← Robot Price Index

GoFa CRB 15000 — 価格・仕様・代替機種(2026年インデックス)

ABB Robotics, Switzerland · 産業用ロボットアーム

市場価格$30,000–$38,000
可搬質量5 kg
リーチ950 mm
主な用途溶接、パレタイジング、マシンテンディング、組立

ABB Robotics(Switzerland)のGoFa CRB 15000は産業用ロボットアーム。指数では2026-10時点で$30,000–$38,000、ステータスは販売中。

販売中
$30,000–$38,000

ABBは公開価格表を持たず、ディストリビューター経由の見積もり販売です。$30,000〜38,000というレンジは、コントローラ込みのGoFa 5ベース構成についてディストリビューター掲載と業界コストガイドから導いた推定値です。ファミリーには上位のGoFa 10/GoFa 12(可搬最大12 kg、リーチ1.62 m)もあります。このレンジは目安でありオファーではありません。

2026-10時点で検証済み · 価格検証の方法

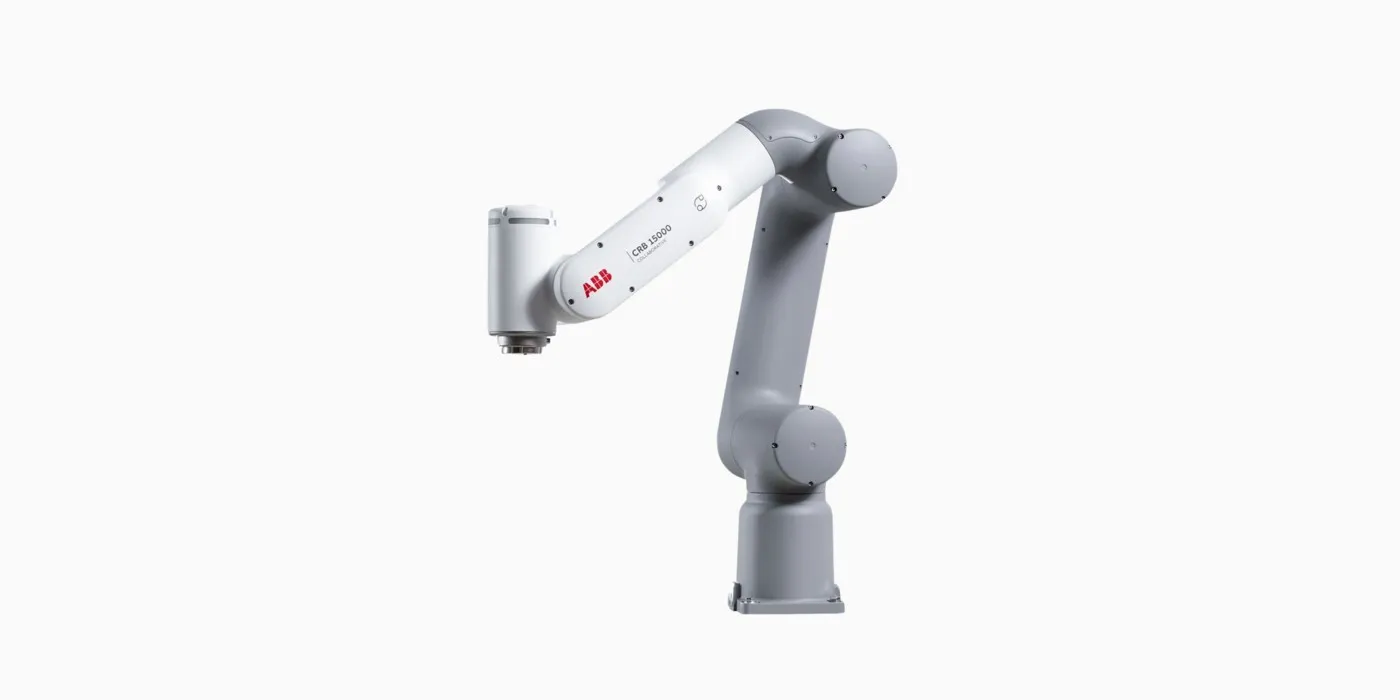
GoFa CRB 15000 — 産業用ロボットアーム
Image: ABB Robotics
カテゴリー
産業用ロボットアーム
重量
27 kg
可搬重量
5 kg
リーチ
950 mm
繰り返し精度
±0.02 mm
消費電力
202 W
自由度
6
IP等級
IP54
発売年
2021
SDK / エコシステム
ABB RobotStudio, Wizard Easy Programming, RAPID
価格履歴(最低価格、USD)2026-08: $30,000 → 2026-10: $30,000

GoFa CRB 15000 とクラス平均

当インデックスからの算出値:各項目を公開している産業用ロボットアームの中央値です。推定は使わず、データの更新に応じて中央値も動きます。 17機種

項目この機種クラス中央値中央値比
価格(レンジ中央)$34,000$21,525×1.58
可搬重量5 kg5 kg×1
リーチ950 mm891 mm×1.07
重量27 kg22 kg×1.23
自由度66×1
可搬1kgあたり価格$6,800$3,591×1.89

代替機種との比較

GoFa CRB 15000 を同クラスの最有力ライバルと比較 — 欧米製と中国製の代替機を価格と主要仕様で並べて掲載。

モデルメーカー価格(USD)可搬重量リーチ販売状況
GoFa CRB 15000ABB Robotics (Switzerland)$30,000–$38,0005 kg950 mm販売中
Dobot CR5 / CR5ADobot Robotics (China)$10,000–$24,3205 kg900 mm販売中
Unitree Z1Unitree Robotics (China)$15,9992 kg700 mm販売中
Motoman HC10DTPYaskawa (Japan)$25,000–$50,00010 kg1379 mm販売中

総保有コスト(TCO)— 目安

当サイトの検証済み価格と業界の経験則から算出したモデル試算です。オファーではありません:正確な金額は工場見積もりで確定します。

コスト項目試算(USD)
本体(インデックス価格)$30,000–$38,000
輸送・輸入+5–12% · $1,500–$4,560
立ち上げ・インテグレーション+30–80% · $9,000–$30,400
保守・サポート(年間)5–10% · $1,500–$3,800
3年間のTCO目安$45,000–$84,360

GoFa CRB 15000 の工場直販見積もりを依頼する。 Robot Price Indexは中国ソーシング企業Dream Viewが発行しています:工場直接購買、出荷前の現地検品、輸出・輸送の手配まで — 手数料は一律10%です。

GoFa CRB 15000 の見積もりを依頼

必要な内容をお知らせください — 1営業日以内に工場直販価格と配送オプションをご返信します。

スパムはありません — ご依頼は当社ソーシングチームに直接届きます。

GoFa CRB 15000のレビュー

検証済みオーナーレビューはまだありません。当サイトはロボットの所有を証明できる方のレビューのみを掲載し、公開済みの第三者テストは要約するだけで、決して書き換えません。

公開レビューTino Sabu (University of Skövde, master's thesis) · Built and tested a HoloLens 2 / Unity mixed-reality pathfinding application driving a real ABB GoFa CRB 15000 to perform obstacle-avoiding pick-and-place tasks at the University of Skövde's Assar Innovation Arena.

The author reports the pathfinding algorithm "effectively determined routes from the starting point to the destination both with and without obstacles, accomplishing the intended task proficiently," but candidly lists integration difficulties, noting that "even minor alterations required the application to undergo a complete rebuilding process, which was also exceptionally time-consuming."

  • Reliably executed pick-and-place tasks along algorithmically generated collision-free paths
  • TCP/IP socket link to Unity worked for real-time control of the physical arm and its gripper
  • RobotStudio SDK streamed live joint values, enabling an accurate digital twin of the robot's motion
  • Establishing communication between the HoloLens/Unity app and the robot controller was a main technical difficulty
  • Achieving smooth robot movement along the planned path required significant troubleshooting
  • Development iteration was slow -- even minor changes forced a full application rebuild

University of Skövde (DiVA portal) master's thesisでレビュー全文を読む →

公開レビューRoman Parak (Brno University of Technology, NETME Centre) · Developed and tested a Unity3D digital-twin application controlling a real ABB GoFa CRB 15000 via Externally Guided Motion over UDP/TCP-IP, including a SCHUNK Co-act gripper, validated on both real hardware and simulation.

The project documentation states the "Unity3D Digital-Twin application has been tested on the ABB CRB GoFa robotic arm, both on real hardware and in simulation," while flagging concrete integration snags found only through hands-on testing.

  • Successfully controlled the real robot's TCP via EGM in Cartesian space directly from a Unity3D app
  • SCHUNK Co-act gripper integration via TCP/IP worked alongside the EGM motion control
  • Multi-threaded implementation ran the digital twin without blocking real-robot communication
  • Real-world control only worked with an older RobotWare version (7.6.1 or lower)
  • Getting the real robot connected required disabling the firewall, a hurdle not mentioned in official documentation

GitHub - rparak/Unity3D_ABB_CRB_15000_GoFa_EGMでレビュー全文を読む →

GoFa CRB 15000をお持ちですか?レビューを書く

オーナーレビューは、このインデックスが唯一計算では出せないものです。だからこそ真剣に扱います:掲載前に所有証明をお願いし、あなたの評価には一切手を加えず、レビューに対価を支払うことは決してありません。連絡先は非公開のままです。

公開前に所有確認のためこちらからご連絡します。スパムもマーケティングもありません。