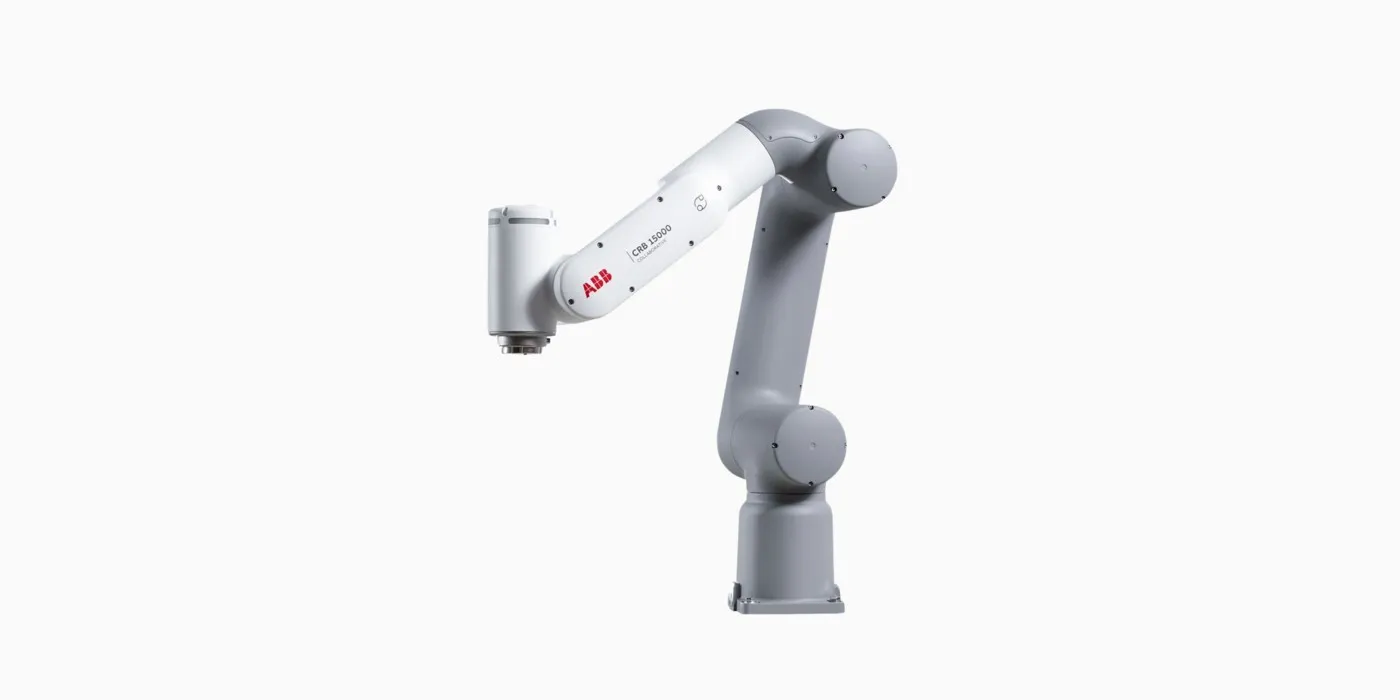
GoFa CRB 15000 by ABB Robotics (Switzerland) is a industrial robot arm; the index lists it at $30,000–$38,000 as of 2026-10, status: for sale.
For sale
$30,000–$38,000
ABB sells through distributors on a quote basis with no public list price; the $30,000-38,000 range is an estimate drawn from distributor listings and industry cost guides for the base GoFa 5 configuration with controller. The family also includes GoFa 10 and GoFa 12 variants at higher price points, with GoFa 12 estimated around $50,000. Treat the range as indicative, not an offer.
Price history (min, USD)2026-08: $30,000 → 2026-10: $30,000
GoFa CRB 15000 vs its class
Computed from this index: medians across the industrial robot arm models that publish each figure. No estimates — the medians move as the data does. 17 models
Metric
This model
Class median
vs median
Price, mid of range
$34,000
$21,525
×1.58
Payload
5 kg
5 kg
×1
Reach
950 mm
891 mm
×1.07
Weight
27 kg
22 kg
×1.23
Degrees of freedom
6
6
×1
Price per kg of payload
$6,800
$3,591
×1.89
Alternatives & how they compare
GoFa CRB 15000 against its closest rivals in this class — Western and Chinese alternatives side by side, by price and key specs.
A model estimate built from our verified price data and industry rules of thumb. Not a vendor offer: exact numbers come with a factory quote.
Cost item
Estimate (USD)
Hardware (index price)
$30,000–$38,000
Delivery & import
+5–12% · $1,500–$4,560
Commissioning & integration
+30–80% · $9,000–$30,400
Maintenance & support, per year
5–10% · $1,500–$3,800
Indicative 3-year TCO
$45,000–$84,360
Request a factory-direct procurement quote for the GoFa CRB 15000. Robot Price Index is published by Dream View, a China-sourcing company: factory-direct purchasing, on-site inspection before shipment, export and freight handled — flat 10% fee.
Get a quote for the GoFa CRB 15000
Tell us what you need — we reply within one business day with factory-direct pricing and delivery options.
GoFa CRB 15000 reviews
No verified owner reviews yet. We publish only reviews from people who can show they own the robot, and we summarise — never rewrite — published third-party tests.
Published reviewTino Sabu (University of Skövde, master's thesis) · Built and tested a HoloLens 2 / Unity mixed-reality pathfinding application driving a real ABB GoFa CRB 15000 to perform obstacle-avoiding pick-and-place tasks at the University of Skövde's Assar Innovation Arena.
The author reports the pathfinding algorithm "effectively determined routes from the starting point to the destination both with and without obstacles, accomplishing the intended task proficiently," but candidly lists integration difficulties, noting that "even minor alterations required the application to undergo a complete rebuilding process, which was also exceptionally time-consuming."
Reliably executed pick-and-place tasks along algorithmically generated collision-free paths
TCP/IP socket link to Unity worked for real-time control of the physical arm and its gripper
RobotStudio SDK streamed live joint values, enabling an accurate digital twin of the robot's motion
Establishing communication between the HoloLens/Unity app and the robot controller was a main technical difficulty
Achieving smooth robot movement along the planned path required significant troubleshooting
Development iteration was slow -- even minor changes forced a full application rebuild
Published reviewRoman Parak (Brno University of Technology, NETME Centre) · Developed and tested a Unity3D digital-twin application controlling a real ABB GoFa CRB 15000 via Externally Guided Motion over UDP/TCP-IP, including a SCHUNK Co-act gripper, validated on both real hardware and simulation.
The project documentation states the "Unity3D Digital-Twin application has been tested on the ABB CRB GoFa robotic arm, both on real hardware and in simulation," while flagging concrete integration snags found only through hands-on testing.
Successfully controlled the real robot's TCP via EGM in Cartesian space directly from a Unity3D app
SCHUNK Co-act gripper integration via TCP/IP worked alongside the EGM motion control
Multi-threaded implementation ran the digital twin without blocking real-robot communication
Real-world control only worked with an older RobotWare version (7.6.1 or lower)
Getting the real robot connected required disabling the firewall, a hurdle not mentioned in official documentation
Owner reviews are the one thing this index cannot compute, so we take them seriously: we ask for proof of ownership before publishing, we never edit your verdict, and we never pay for reviews. Your contact details stay private.